カテゴリを見る
Keyence KV-XH04ML モーションコントロールモジュール - 中古
説明
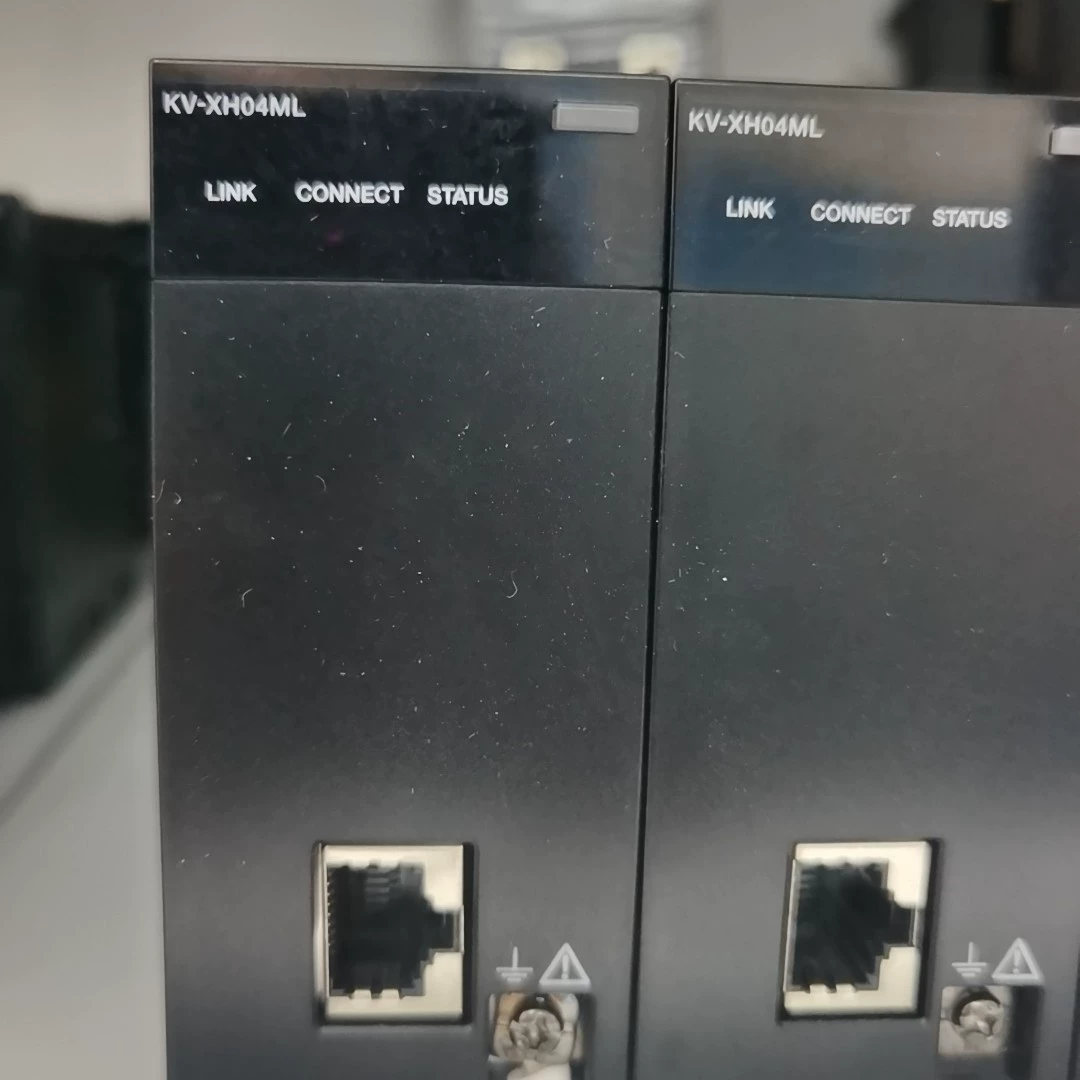
Keyence KV-XH04ML モーションコントロールモジュール(中古)。本機は装置から取り外され、使用に伴う若干の傷みがありますが、コネクタのラッチはすべて揃っています。
仕様
| Brand | Keyence |
|---|---|
| Model | KV-XH04ML |
| Position setting range | -2147483648 to +2147483647 specification units |
| Weight | Approx. 190 g |
| Acceleration/deceleration curve | Linear, SIN |
| Acceleration/deceleration time | 0 to 65535 ms |
| Appropriated device | Relay: 576 points (36 channels) Data memory: 4 words |
| Axis control function execution method | Ladder program, unit program (flow) |
| Cam | Resolution: 2048 to 32768, Data points: 4 to 64 (changes according to the resolution) |
| Clutch | Select from direct, slide, and follow-up |
| Compensation during operation | Compensation via auxiliary input, phase compensation, and step angle compensation |
| Connectable CPU unit | KV-X Series/KV-8000A |
| Control mode | Positioning control, Torque control, Speed control, ML-III command, I/O control |
| Control period | 500 μs or more |
| Cumulative address | -2147483648 to +2147483647 specification units |
| Data backup | Coordinates: nonvolatile memory backup (unlimited), Parameter settings: flash ROM backup (20000 switches) |
| Input | External reference, instruction coordinates, current coordinates |
| Input filter | Interference prevention function |
| Internal current consumption | ≤160 mA |
| Internal data Memory | 524288 words |
| Interpolation | Linear interpolation, arc interpolation, helical interpolation |
| JOG/inching | JOG (high speed/low speed), inching (specifiable pulses) |
| M-code | 1 to 65000, WITH/AFTER mode |
| Max. number of connectable units | 16 |
| Max. number of flows | 256 |
| Memory data | Point parameters (each axis), synchronization parameters (each axis), cam data, unit program, servo parameters, setting read/write during RUN (with some restrictions) |
| No. of control axes | 4 axes (total including virtual axes) |
| Number of points | 100 points/axis (Trajectory control at 100 points or more possible with flows) |
| Number of simultaneous activities | No upper limit |
| Output display | LINK, CONNECT, error status |
| Output format | MECHATROLINK-III |
| Parameter setting | Parameters can be set from KV STUDIO, ladder programs, and unit programs |
| Position unit | mm, inch, deg (angle), PLS (number of pulses); Decimal point position from 0 to 9 digits, unit conversion function available |
| Positioning mode | Absolute value/relative value |
| Refresh | Automatic refresh, direct refresh, synchronous refresh between units |
| Self-diagnosis function | Diagnosis can be made through hardware errors, various parameter errors, error numbers, and error messages |
| Sensor positioning | External input-based switching control from speed to position |
| Single operation address | -2147483648 to +2147483647 specification units |
| Special function | Synchronous tracking control, absolute position tracking control |
| Starting time | 500 μs |
| Teaching | Current coordinate teaching |
| Type | Positioning/Motion unit |
| Unit program capacity | 3 MB (Max. number of blocks: 20000) |